Scanning, alignment and CNC automation
Measure the real part.
Then machine it.
A 3D scanner on the robot flange finds out where a part actually is and what shape it actually came out. From that one measurement these tools align it to the machine, rebuild it as editable CAD, and show the mill how much material is left to take off.
- Align a part to a KUKA with a scanner or a probe, in robot coordinates.
- Reverse engineer a part with no CAD into an editable STEP file.
- See the remaining stock on a 3D-printed mould before it goes on the mill.
On the machine
Find out where the part really is
A part clamped on a bed is never exactly where the CAD says it is. A Zivid 3D camera rides the KUKA flange, captures the part from a few angles, and the tools work out the transform between the drawing and the metal — so the machine cuts where the part actually sits.
- The scan is the measurement, so it never moves. The CAD is placed onto it.
- The search starts from many orientations and keeps the pose that explains the most measured points.
- You get the numbers before anything is cut — here, 0.42 mm mean deviation.
Shots that merge themselves
The camera is calibrated to the flange once per machine. After that every shot is stamped with the live robot pose and merges into one cloud in KUKA BASE coordinates — no manual stitching, no target spheres on the bed.
The CAD walks onto the scan
Automatic alignment searches from many starting rotations and scores each candidate on how much of the measurement it actually explains, so a partial scan or a symmetric part does not quietly land the wrong way round.
Numbers, then metal
Heat maps colour the CAD by how far the scan sits from it, with mean, RMS and max deviation and how much of the surface was covered. Grey means the scan never saw it — stated, not guessed.
Probe, bed and targets
No scanner on the cell? Touch the same features with the robot probe instead. Scan the bed to see how flat and how level it really is, and cut small locating divots into a printed part so the robot can re-find it tomorrow.
No drawing? No problem
Reverse engineer a part into editable CAD
Scan a physical part, or drop in an STL. Design-intent recognition finds every feature the way a designer drew it — flats, holes, fillets, cones, sketched profiles — and reconstructs the original modelling intent. You get a B-rep STEP file you can open and edit in Fusion, SolidWorks or NX. Not a mesh wrap.
- Every candidate feature is checked against your scan before it is accepted.
- A per-point deviation heat map, with mean, RMS, max and surface coverage.
- A feature timeline — the build steps the part is made of, recovered from a scan.
- A numeric acceptance gate. A poor fit says so, loudly, instead of shipping quietly.
- An STL is recognised back into its real CAD faces — the face count of the original drawing.
- Reads PLY, PCD, XYZ/CSV, STL, OBJ, GLB, E57 and NPY.
- 1 The measurement. The bracket as the camera saw it — a point cloud, noise and all.
- 2 The rebuild. The same part written back as a CAD solid, with real edges and holes.
- 3 The proof. Coloured by how far the model sits from the scan that made it.
Print, then machine
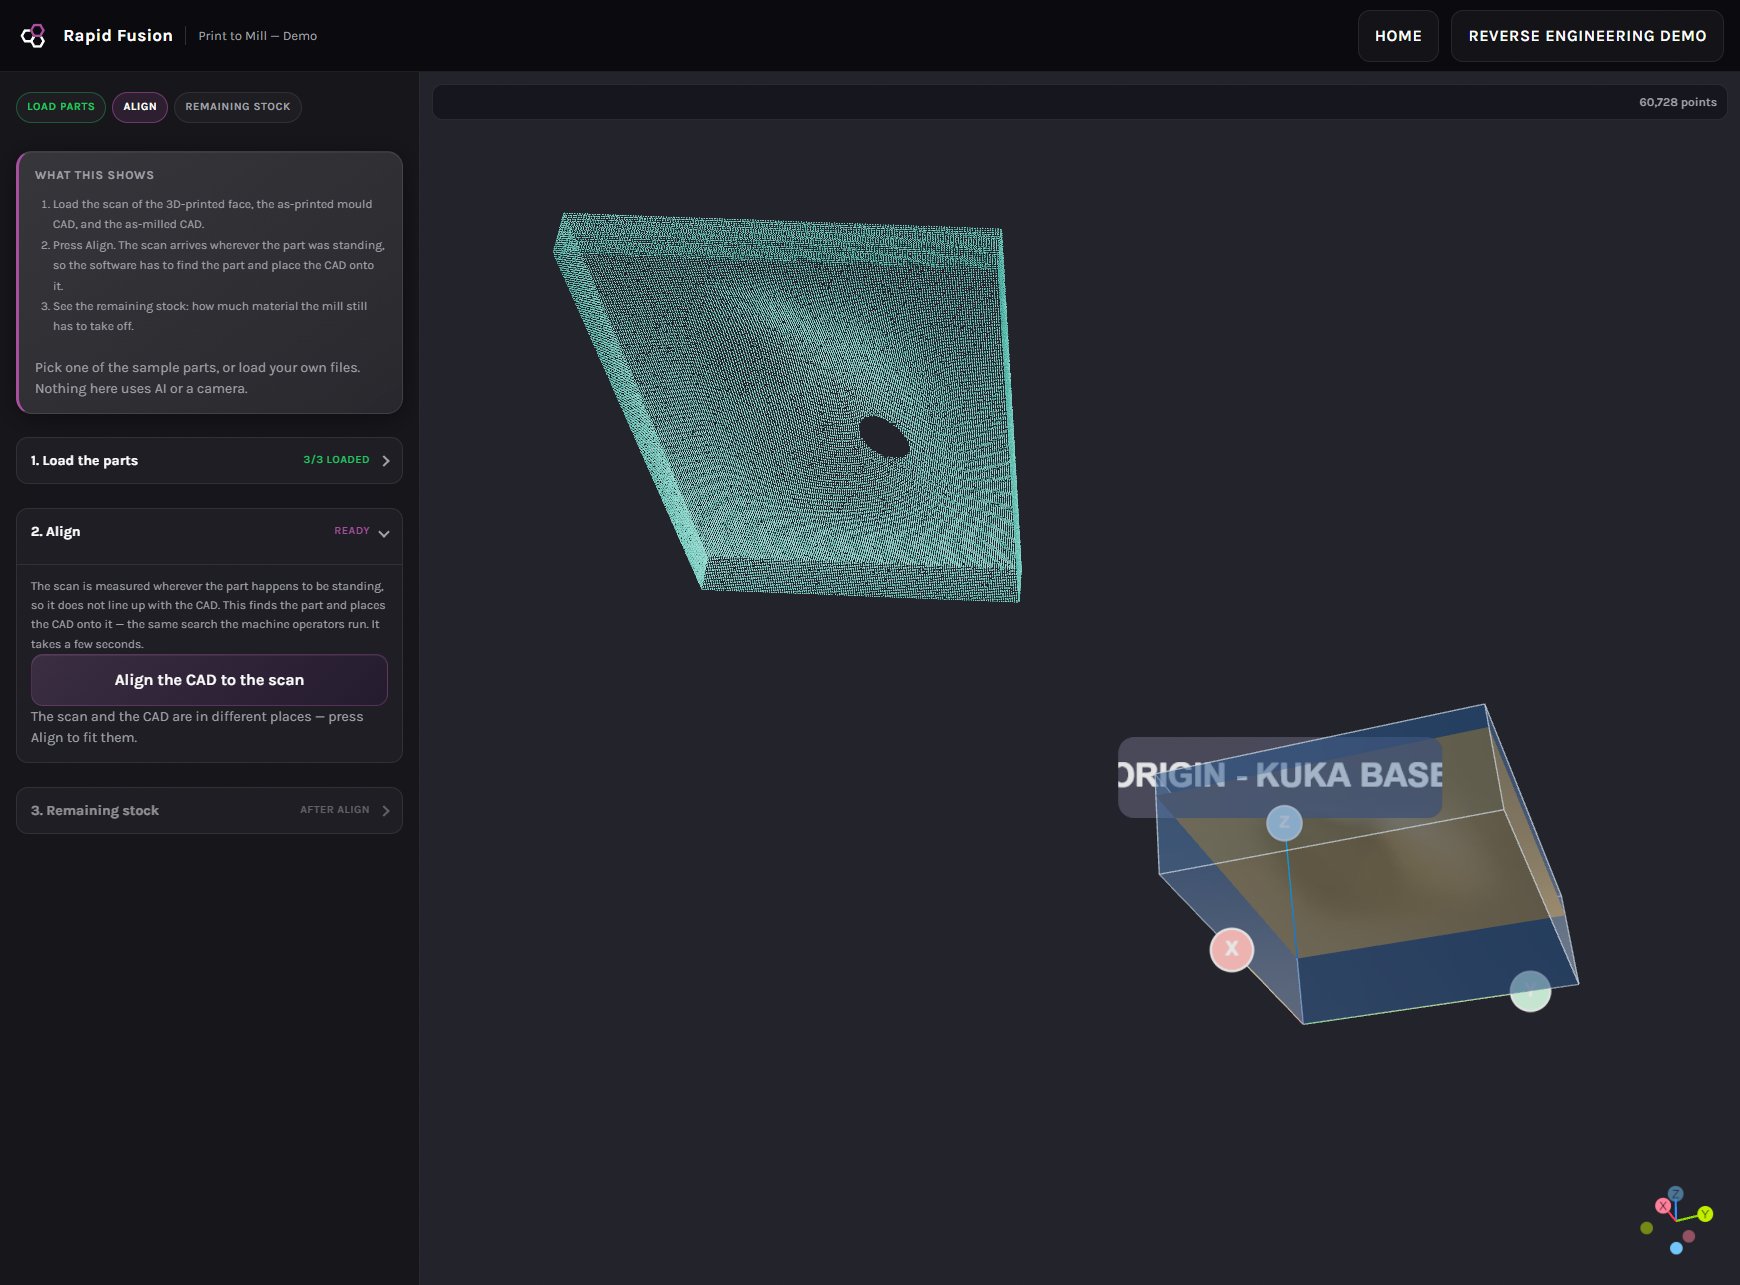
How much stock is left for the mill?
Large moulds get 3D printed with material left on, then finished on the mill. Print it slightly under and the finished surface is scrap. Load the scan of the printed face, the as-printed CAD and the as-milled target: the tool finds the part and colours the surface green where there is enough material to machine and red where there is not.
- Five sample moulds, each printed with a different stock allowance, to try it on.
- Set the minimum stock you need to leave and the map moves with it.
- The same view shows print accuracy — how closely the print matched its own CAD.
- No camera needed — just the three files.
One account, every machine
Rapid Fusion Fleet
The Fleet is the dashboard over every Rapid Fusion machine you own, wherever in the world it is standing. It also owns the accounts: the email and password you use here are your Fleet account, so there is one sign-in, one list of people and one place to grant or remove access.
Live, from anywhere
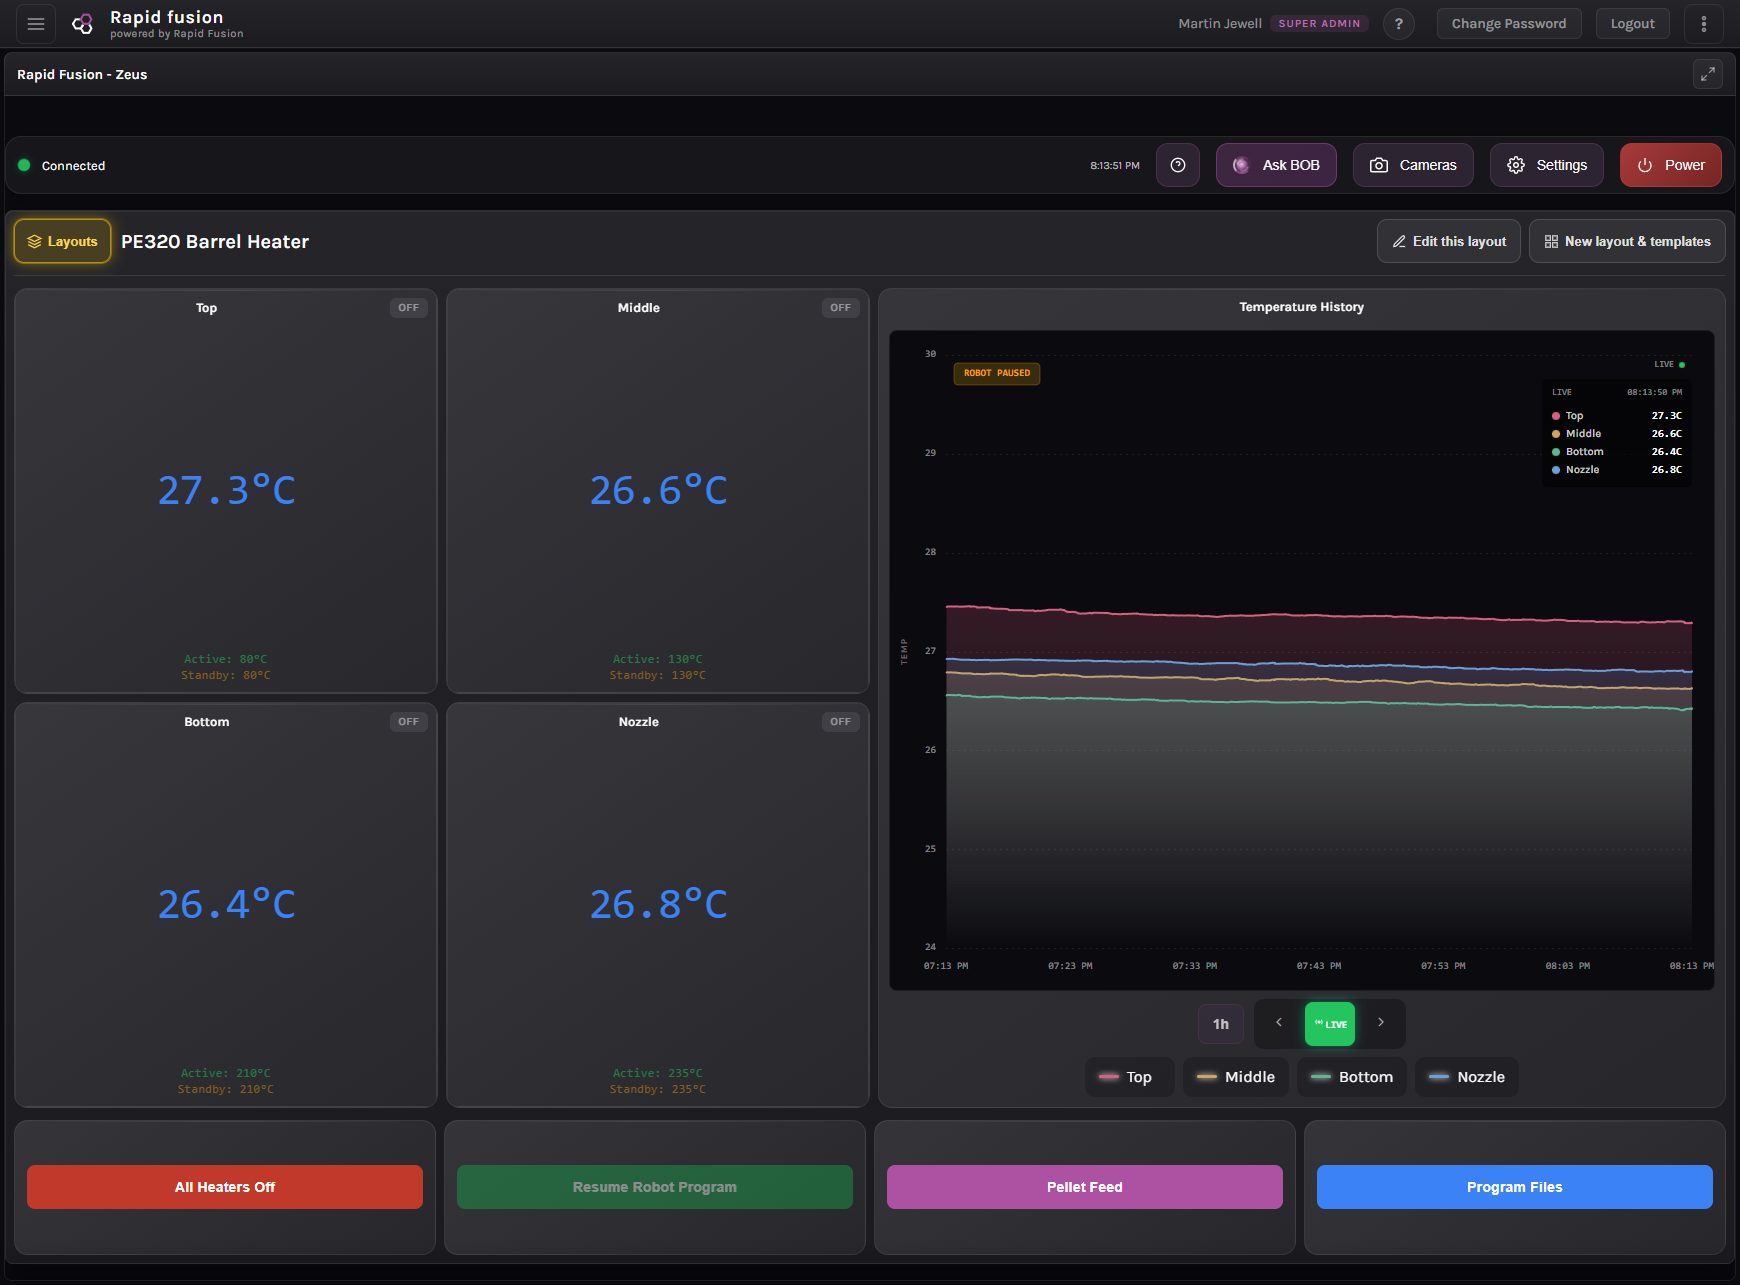
Open a machine and run it, from wherever you are
This is not a status page. Open a machine from the Fleet and you get its real control screen, live: every heater zone reading to a tenth of a degree, the temperature history charting as it happens, the cameras, and the buttons that actually do things — heaters off, resume the robot programme, feed pellets, send program files.
- An engineer in the office can see and fix what an operator is looking at, on a machine in another country.
- The same screen the operator has at the machine, so nobody is describing it down a phone.
- No VPN, no remote-desktop session, no separate app — it is the Fleet, signed in as you.
- Who may press what is your Fleet roles, so looking and doing are not the same permission.
Ask BOB
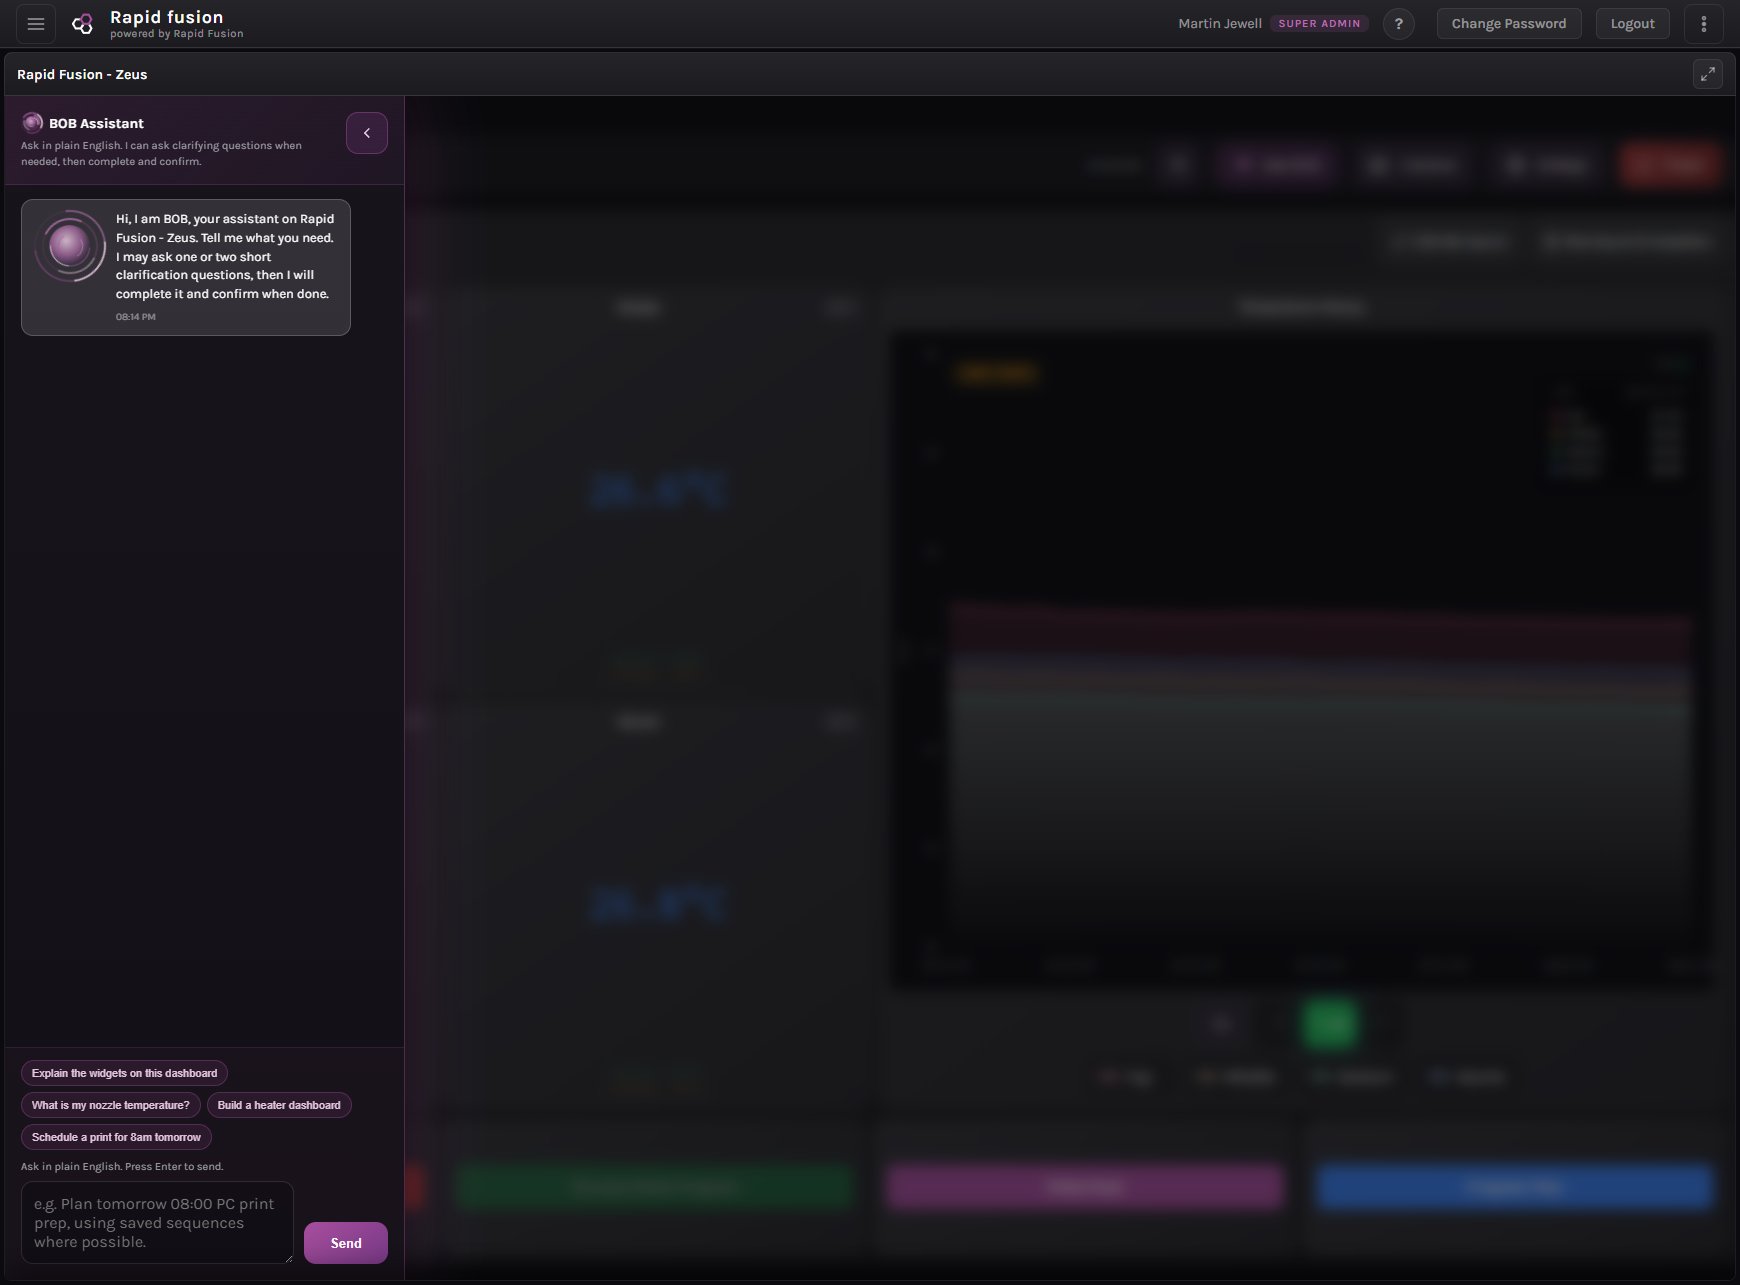
Tell the machine what you need, in plain English
BOB sits on every machine. Ask it a question and it answers from that machine's live state; ask it to do something and it does it — builds you a heater dashboard, schedules tomorrow's print, prepares a run from your saved sequences. It asks a short clarifying question when it needs one, then confirms when the job is done.
- “What is my nozzle temperature?” — answered from the machine in front of you, not a manual.
- “Build a heater dashboard” — and the screen is there, ready to use.
- “Plan tomorrow 08:00 PC print prep, using saved sequences where possible.”
- It works inside your Fleet permissions, so it can only do what you could do yourself.
Every machine, live
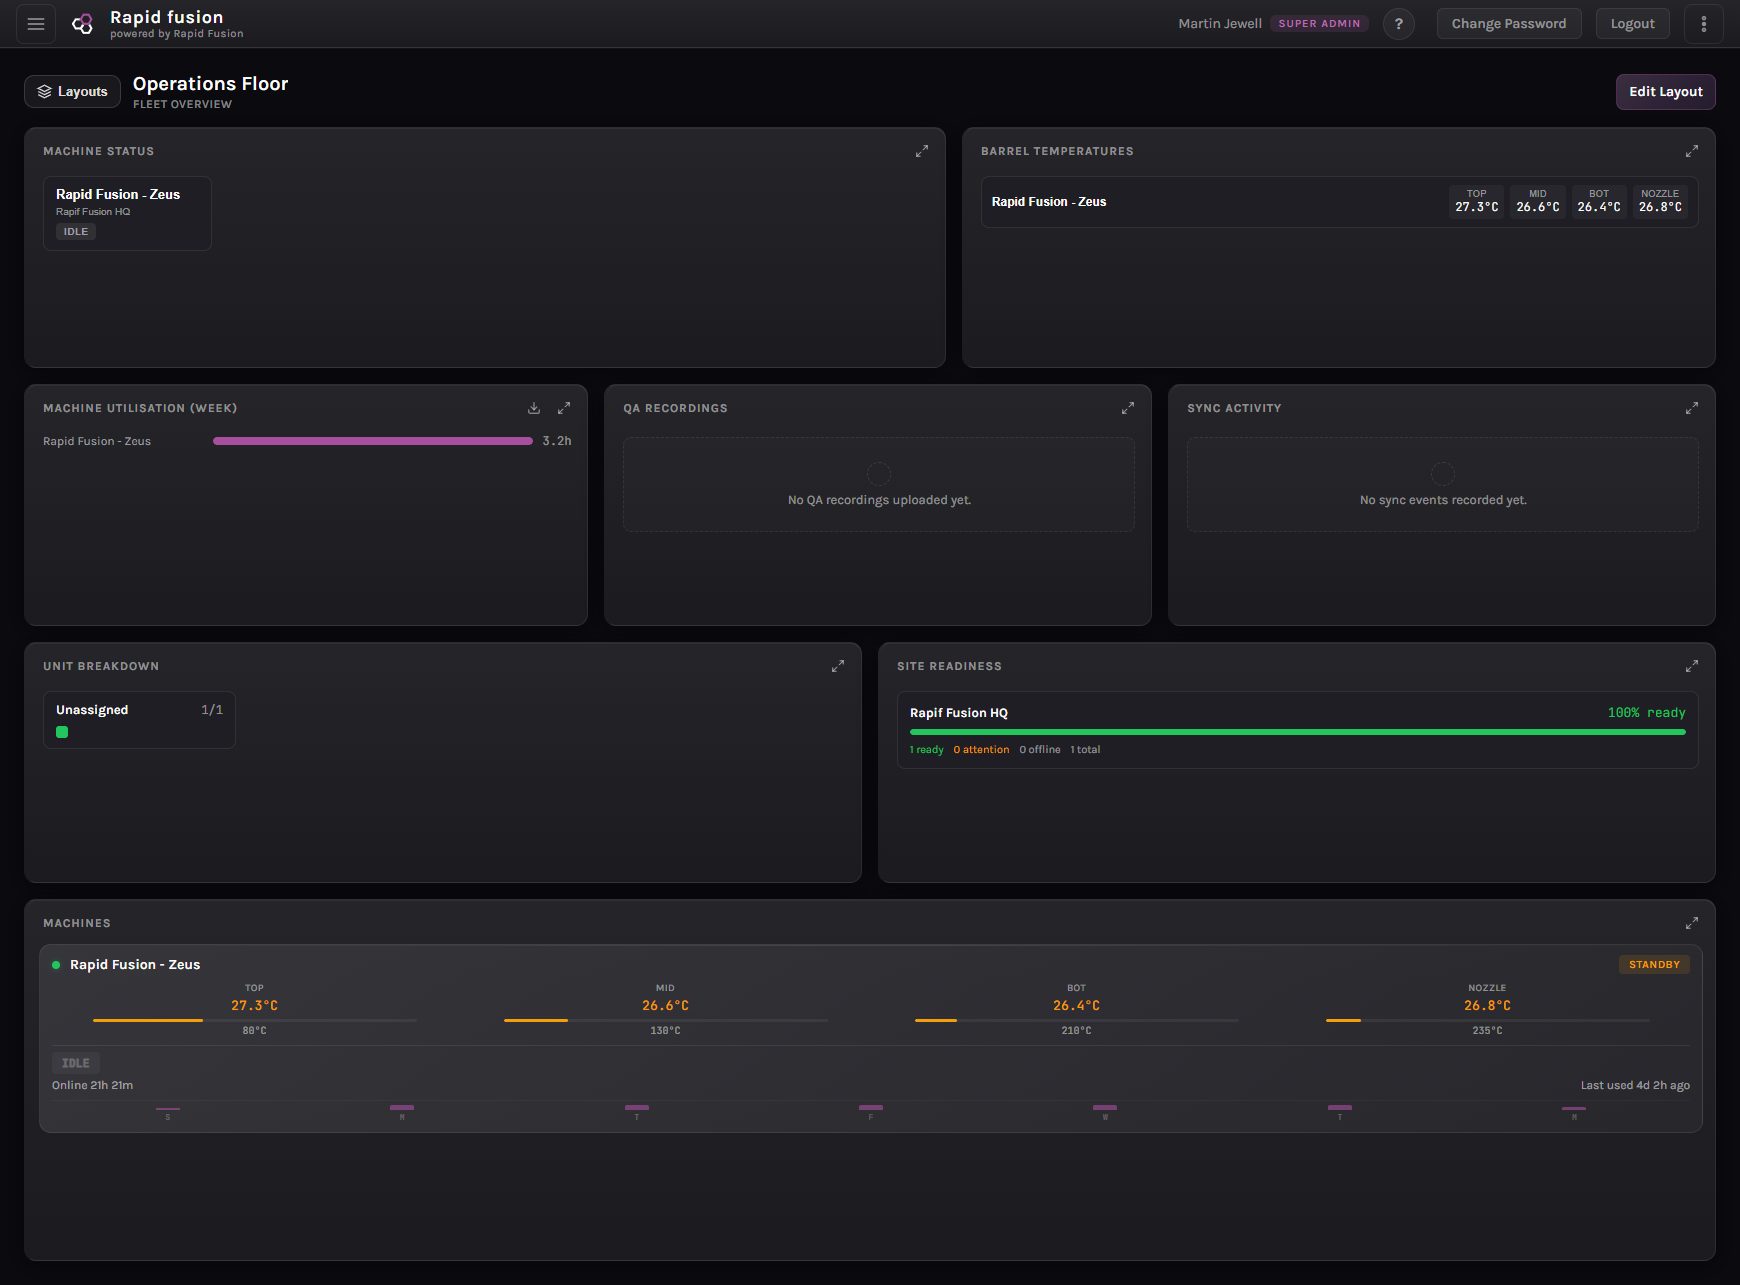
Status, temperatures, utilisation, alerts and energy cost across the fleet, on a dashboard you lay out yourself from a library of widgets.
Sites on a map
Where each machine is and how each site is doing, on a world map and a globe view — built for fleets spread across several countries.
Organisation management
Your organisation structure, its people and exactly what each role may do. Change somebody's access once and it applies to the machines and to these tools.
Send work to a machine
Push print files and slicer profiles out to a machine or a whole site from one place, and keep the quality records that come back.
These tools, inside the Fleet
The scanning and CNC tools on this site open as a workspace in the Fleet dashboard, already signed in, pointed at the machine you picked.
One sign-in, revoked once
The Fleet owns the password and the roles. A person removed at the Fleet loses these tools within minutes, without anybody touching this app.
Put your own part through it.
Sign up with your work email and you get the demo part library, the scan-to-mill workflow, and one free reconstruction of a point cloud of your own.
Takes under a minute. No card required.